A "Proper" Robot
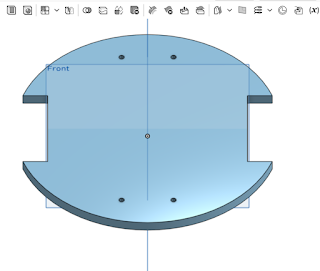
It seems to be that this time each year I introduce a new project, and 2019 not going to be any exception. My projects have become increasingly complex in recent years, and whilst I am still spending a lot of time on autonomous vehicles, according to feedback I have received, it is time to launch something that most enthusiasts could build if they wish. So, what does the list of requirements look like this time? I am still drawing this one up, so as usual, you can follow the build and watch it evolve. For now, here is what I have decided: The finished cost needs to be less that $A300. Before you groan and say that it's way too expensive, Auric cost about eight times that amount, and is still not done. I'm going to use off-the-shelf parts, especially from those low-cost marketplaces. You can use upscale parts if you want, but you don't need to. Use a Raspberry Pi as the controller, and integrate all motion control. The code for the autonomou...